
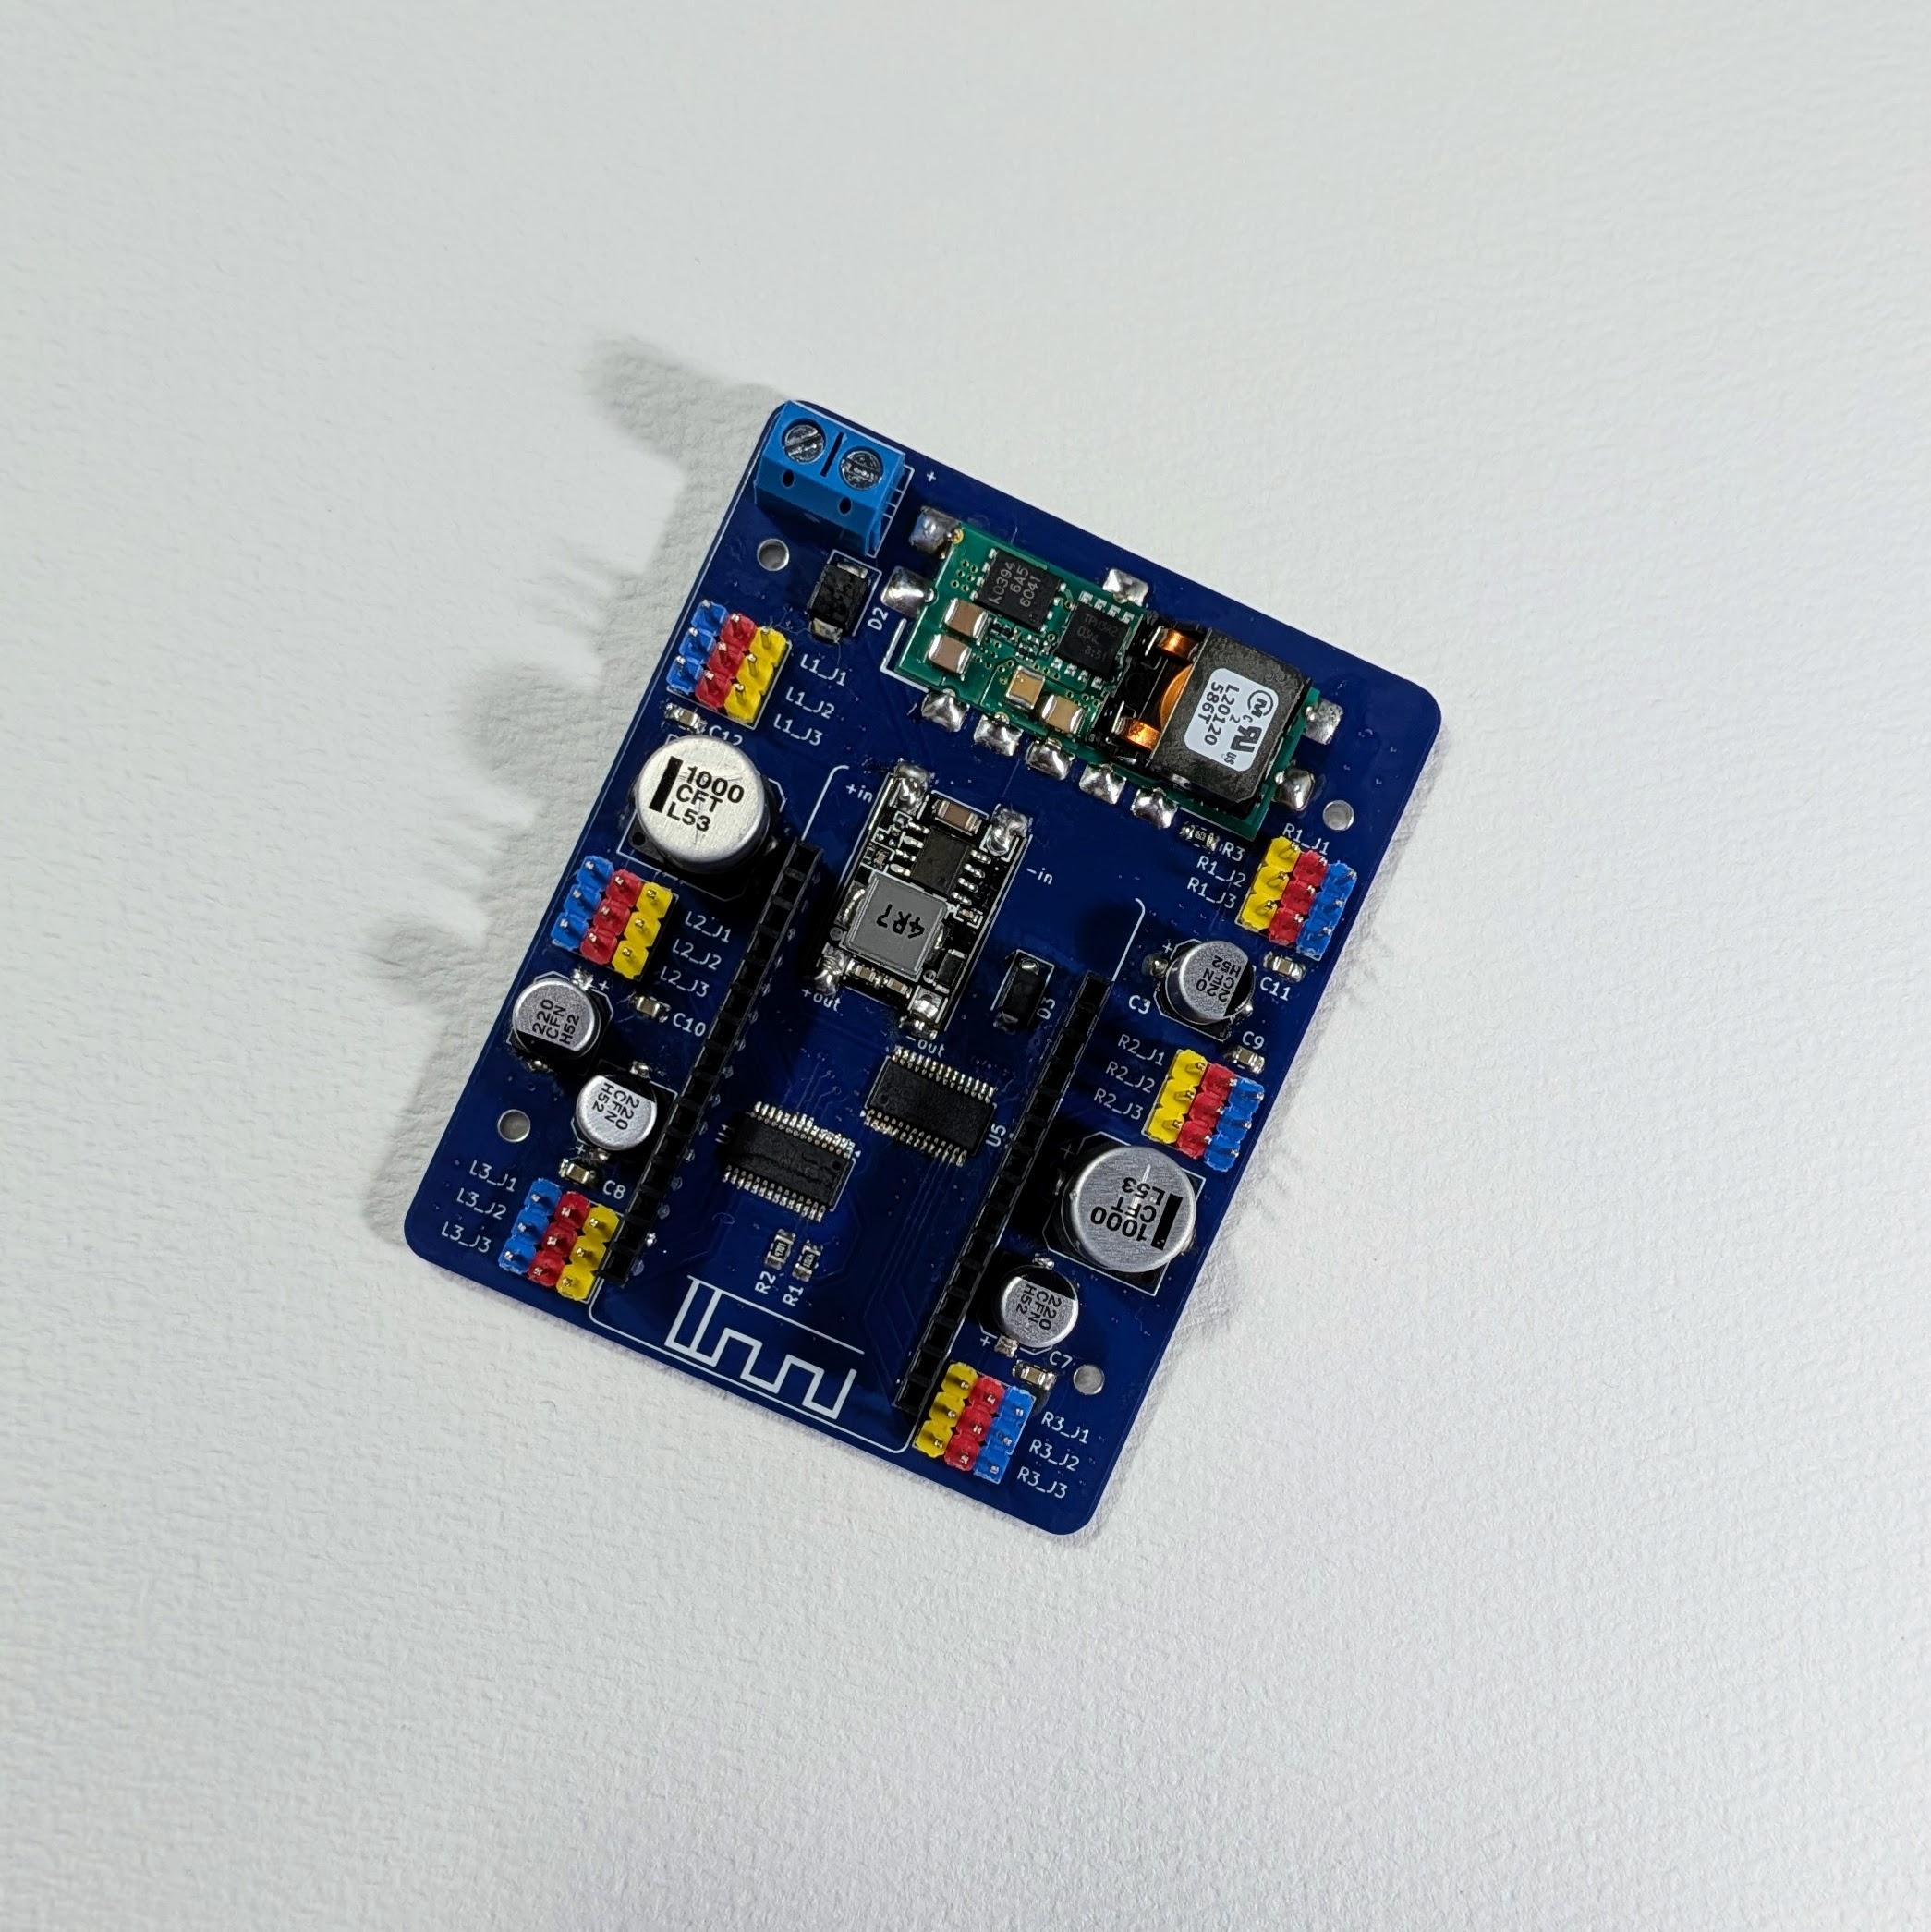
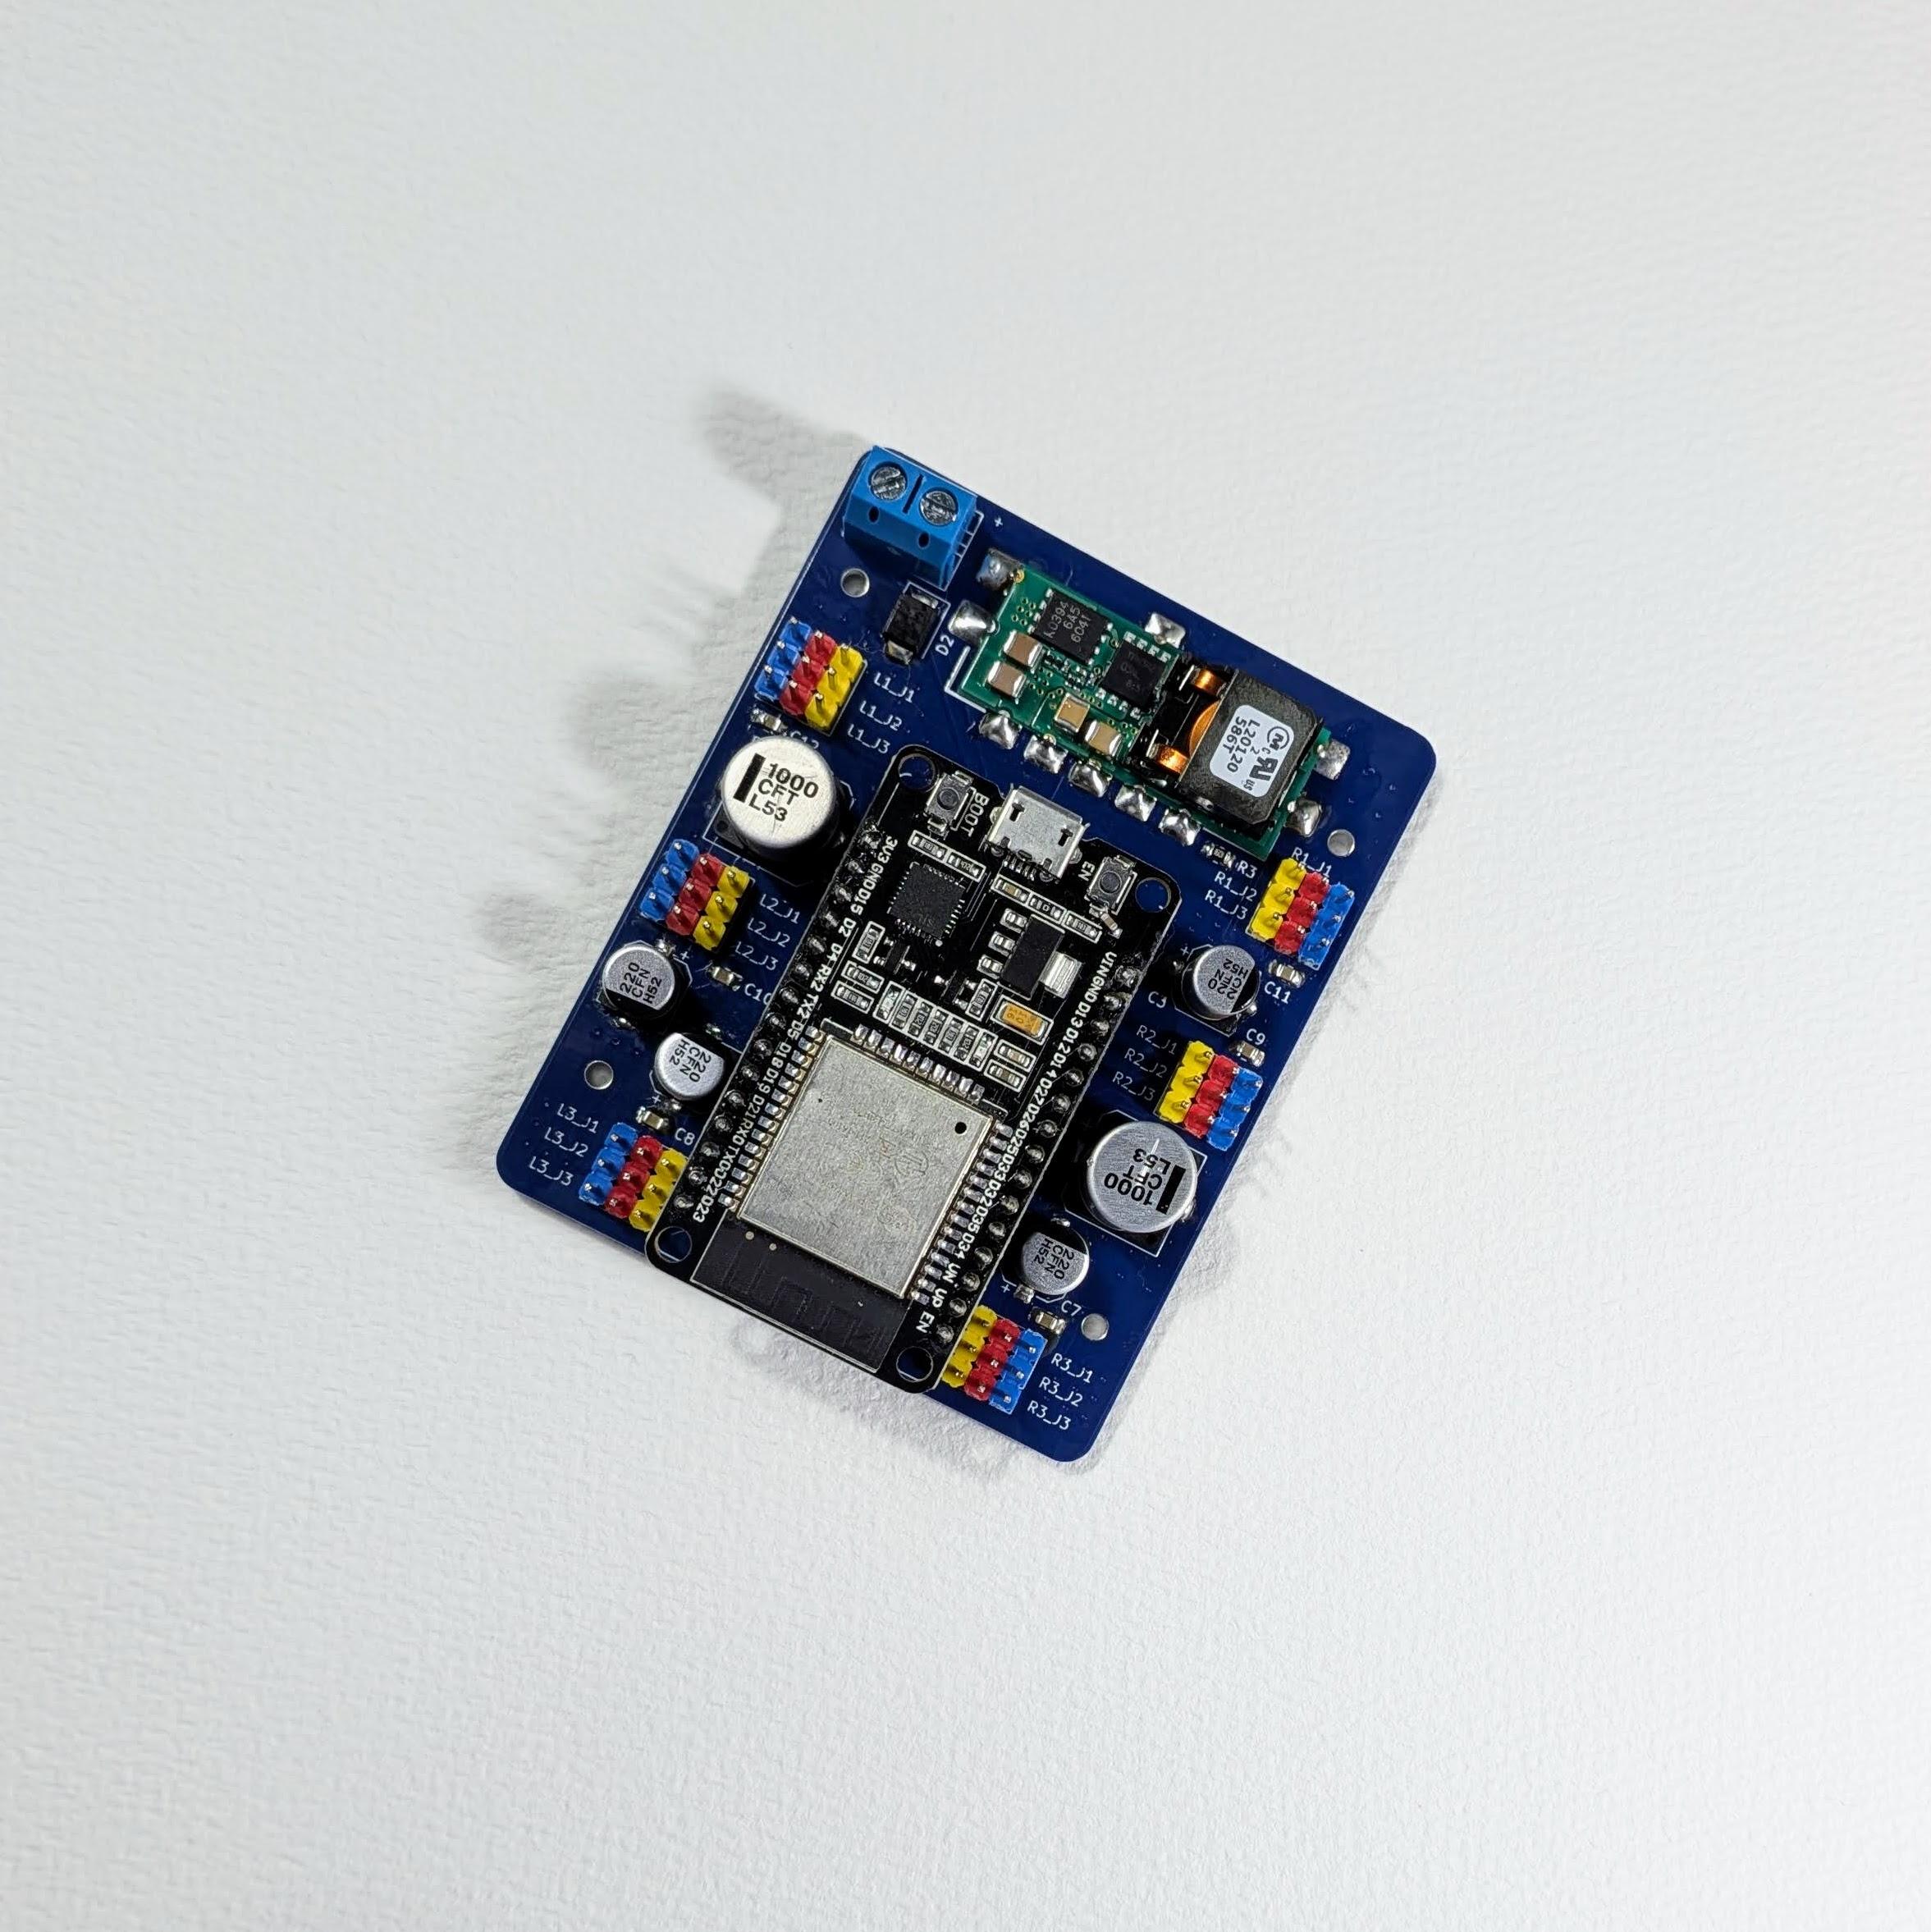
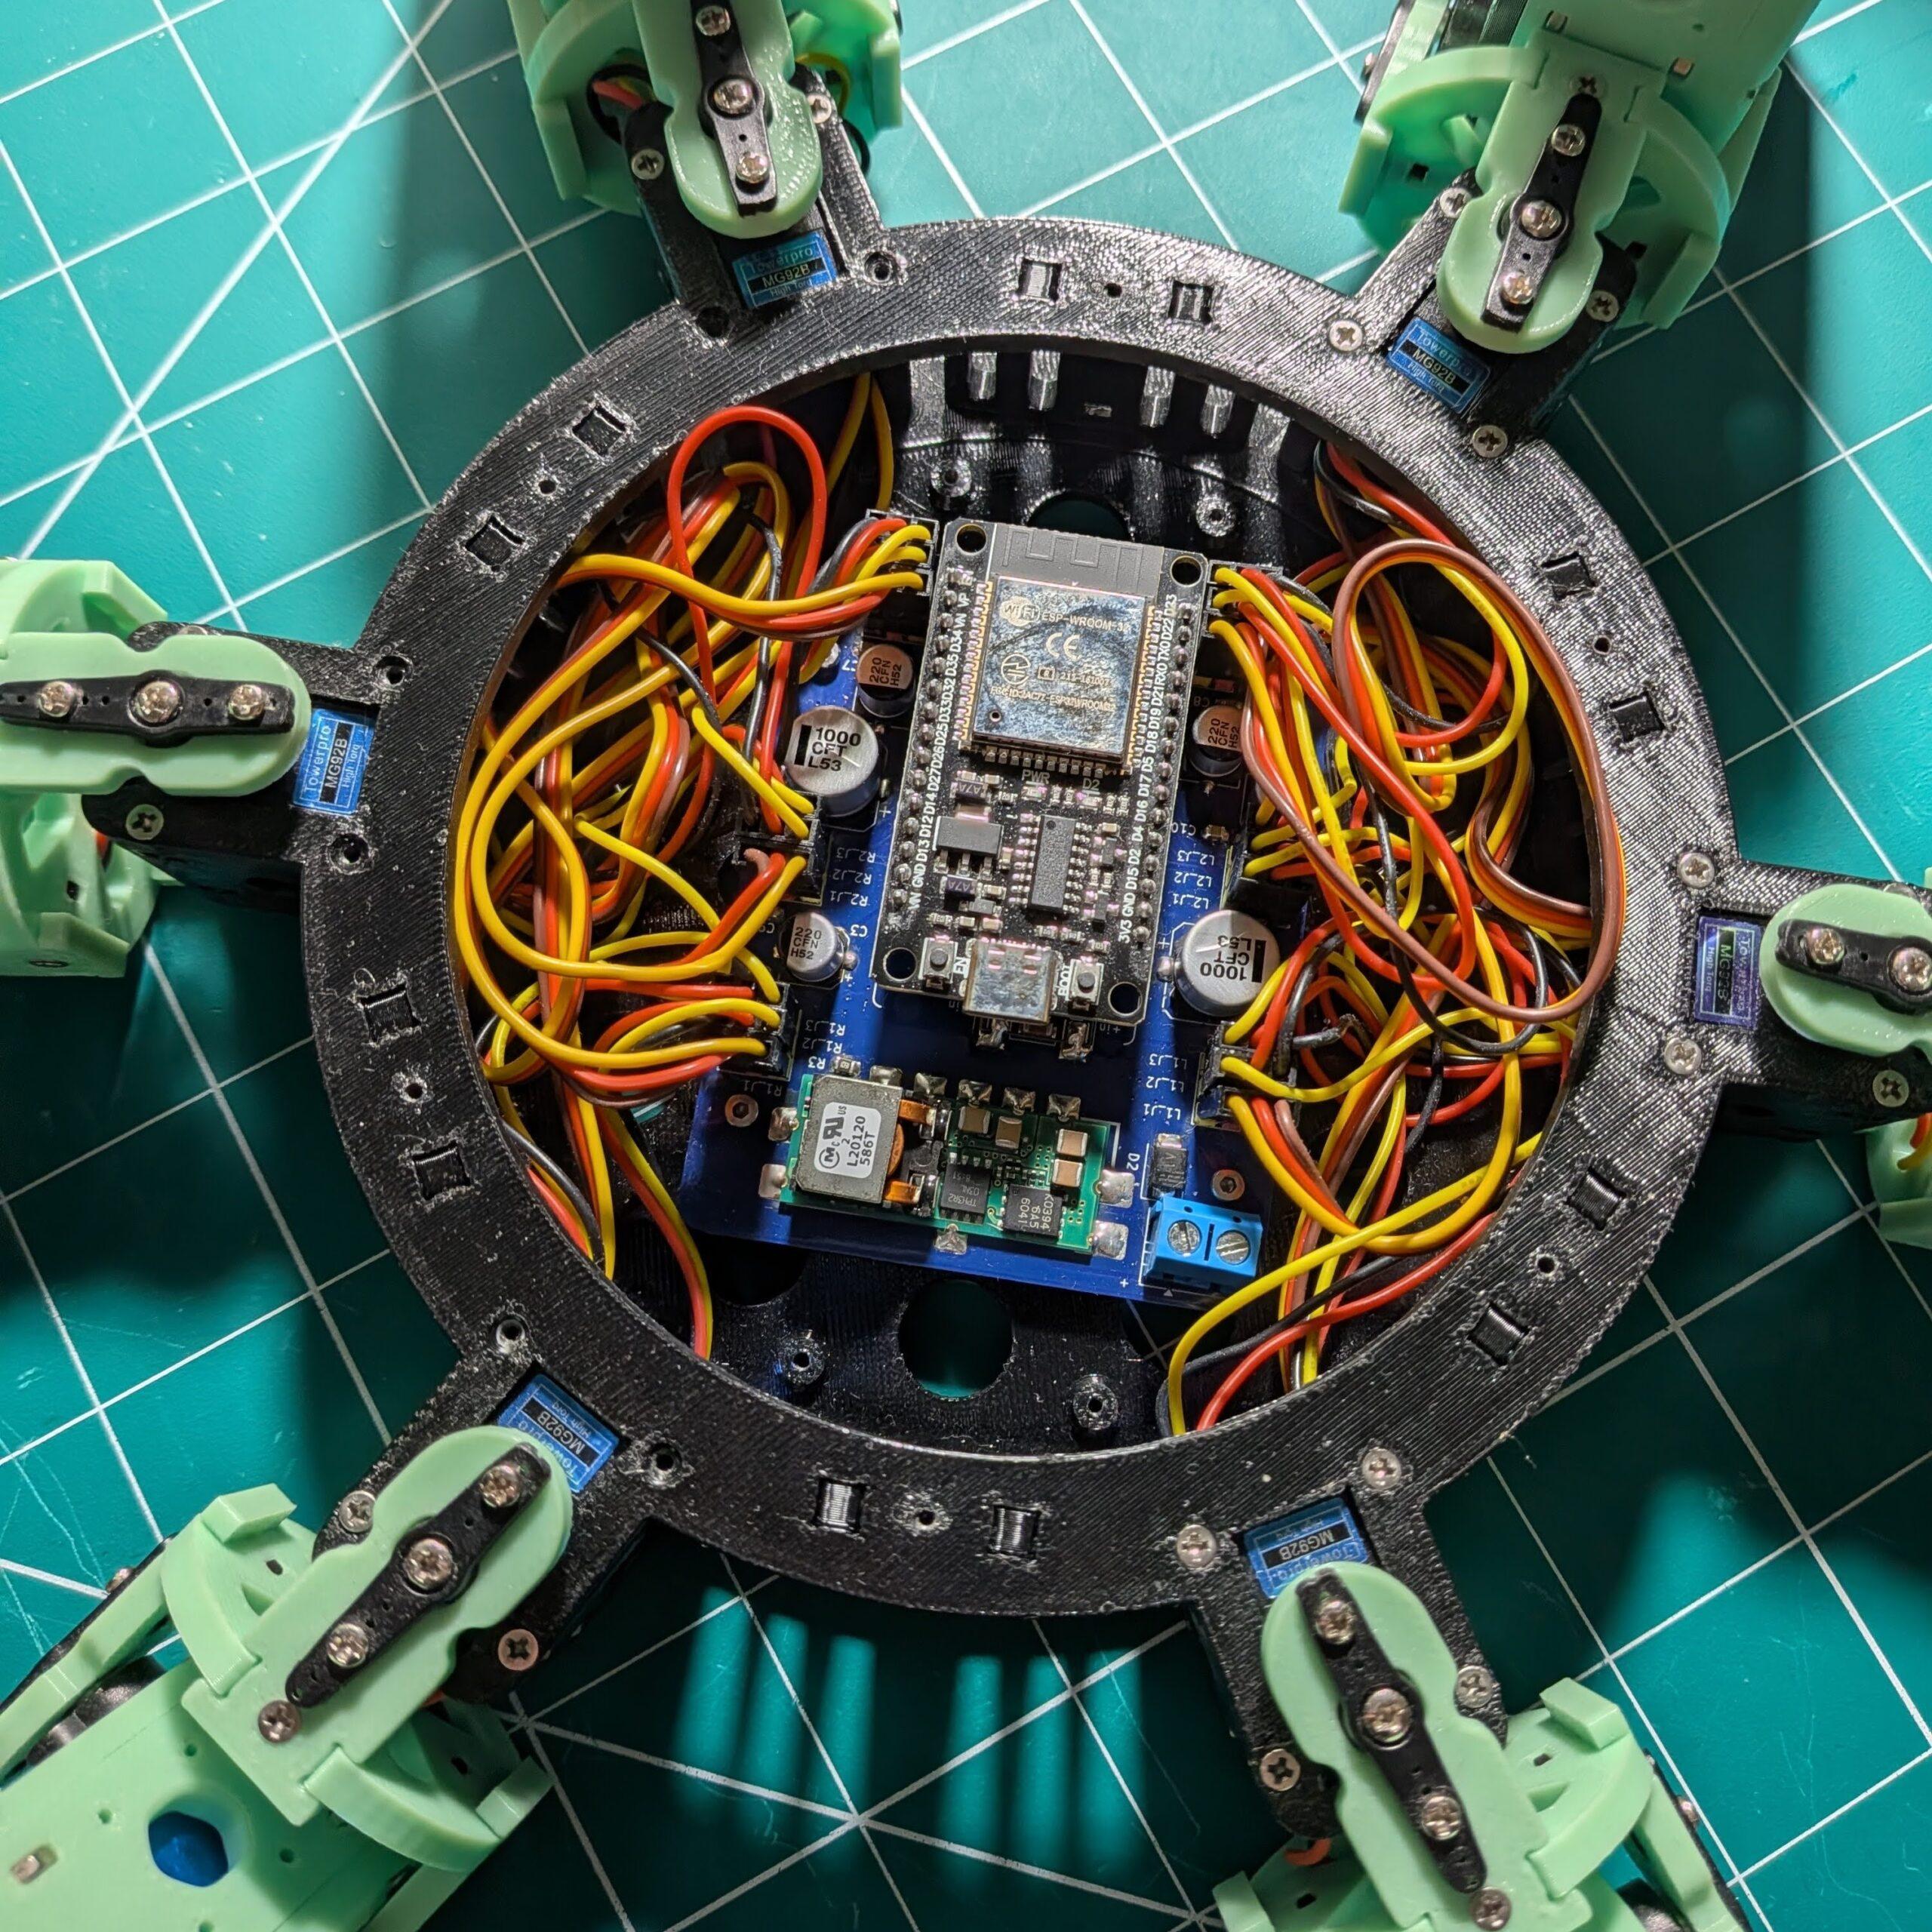
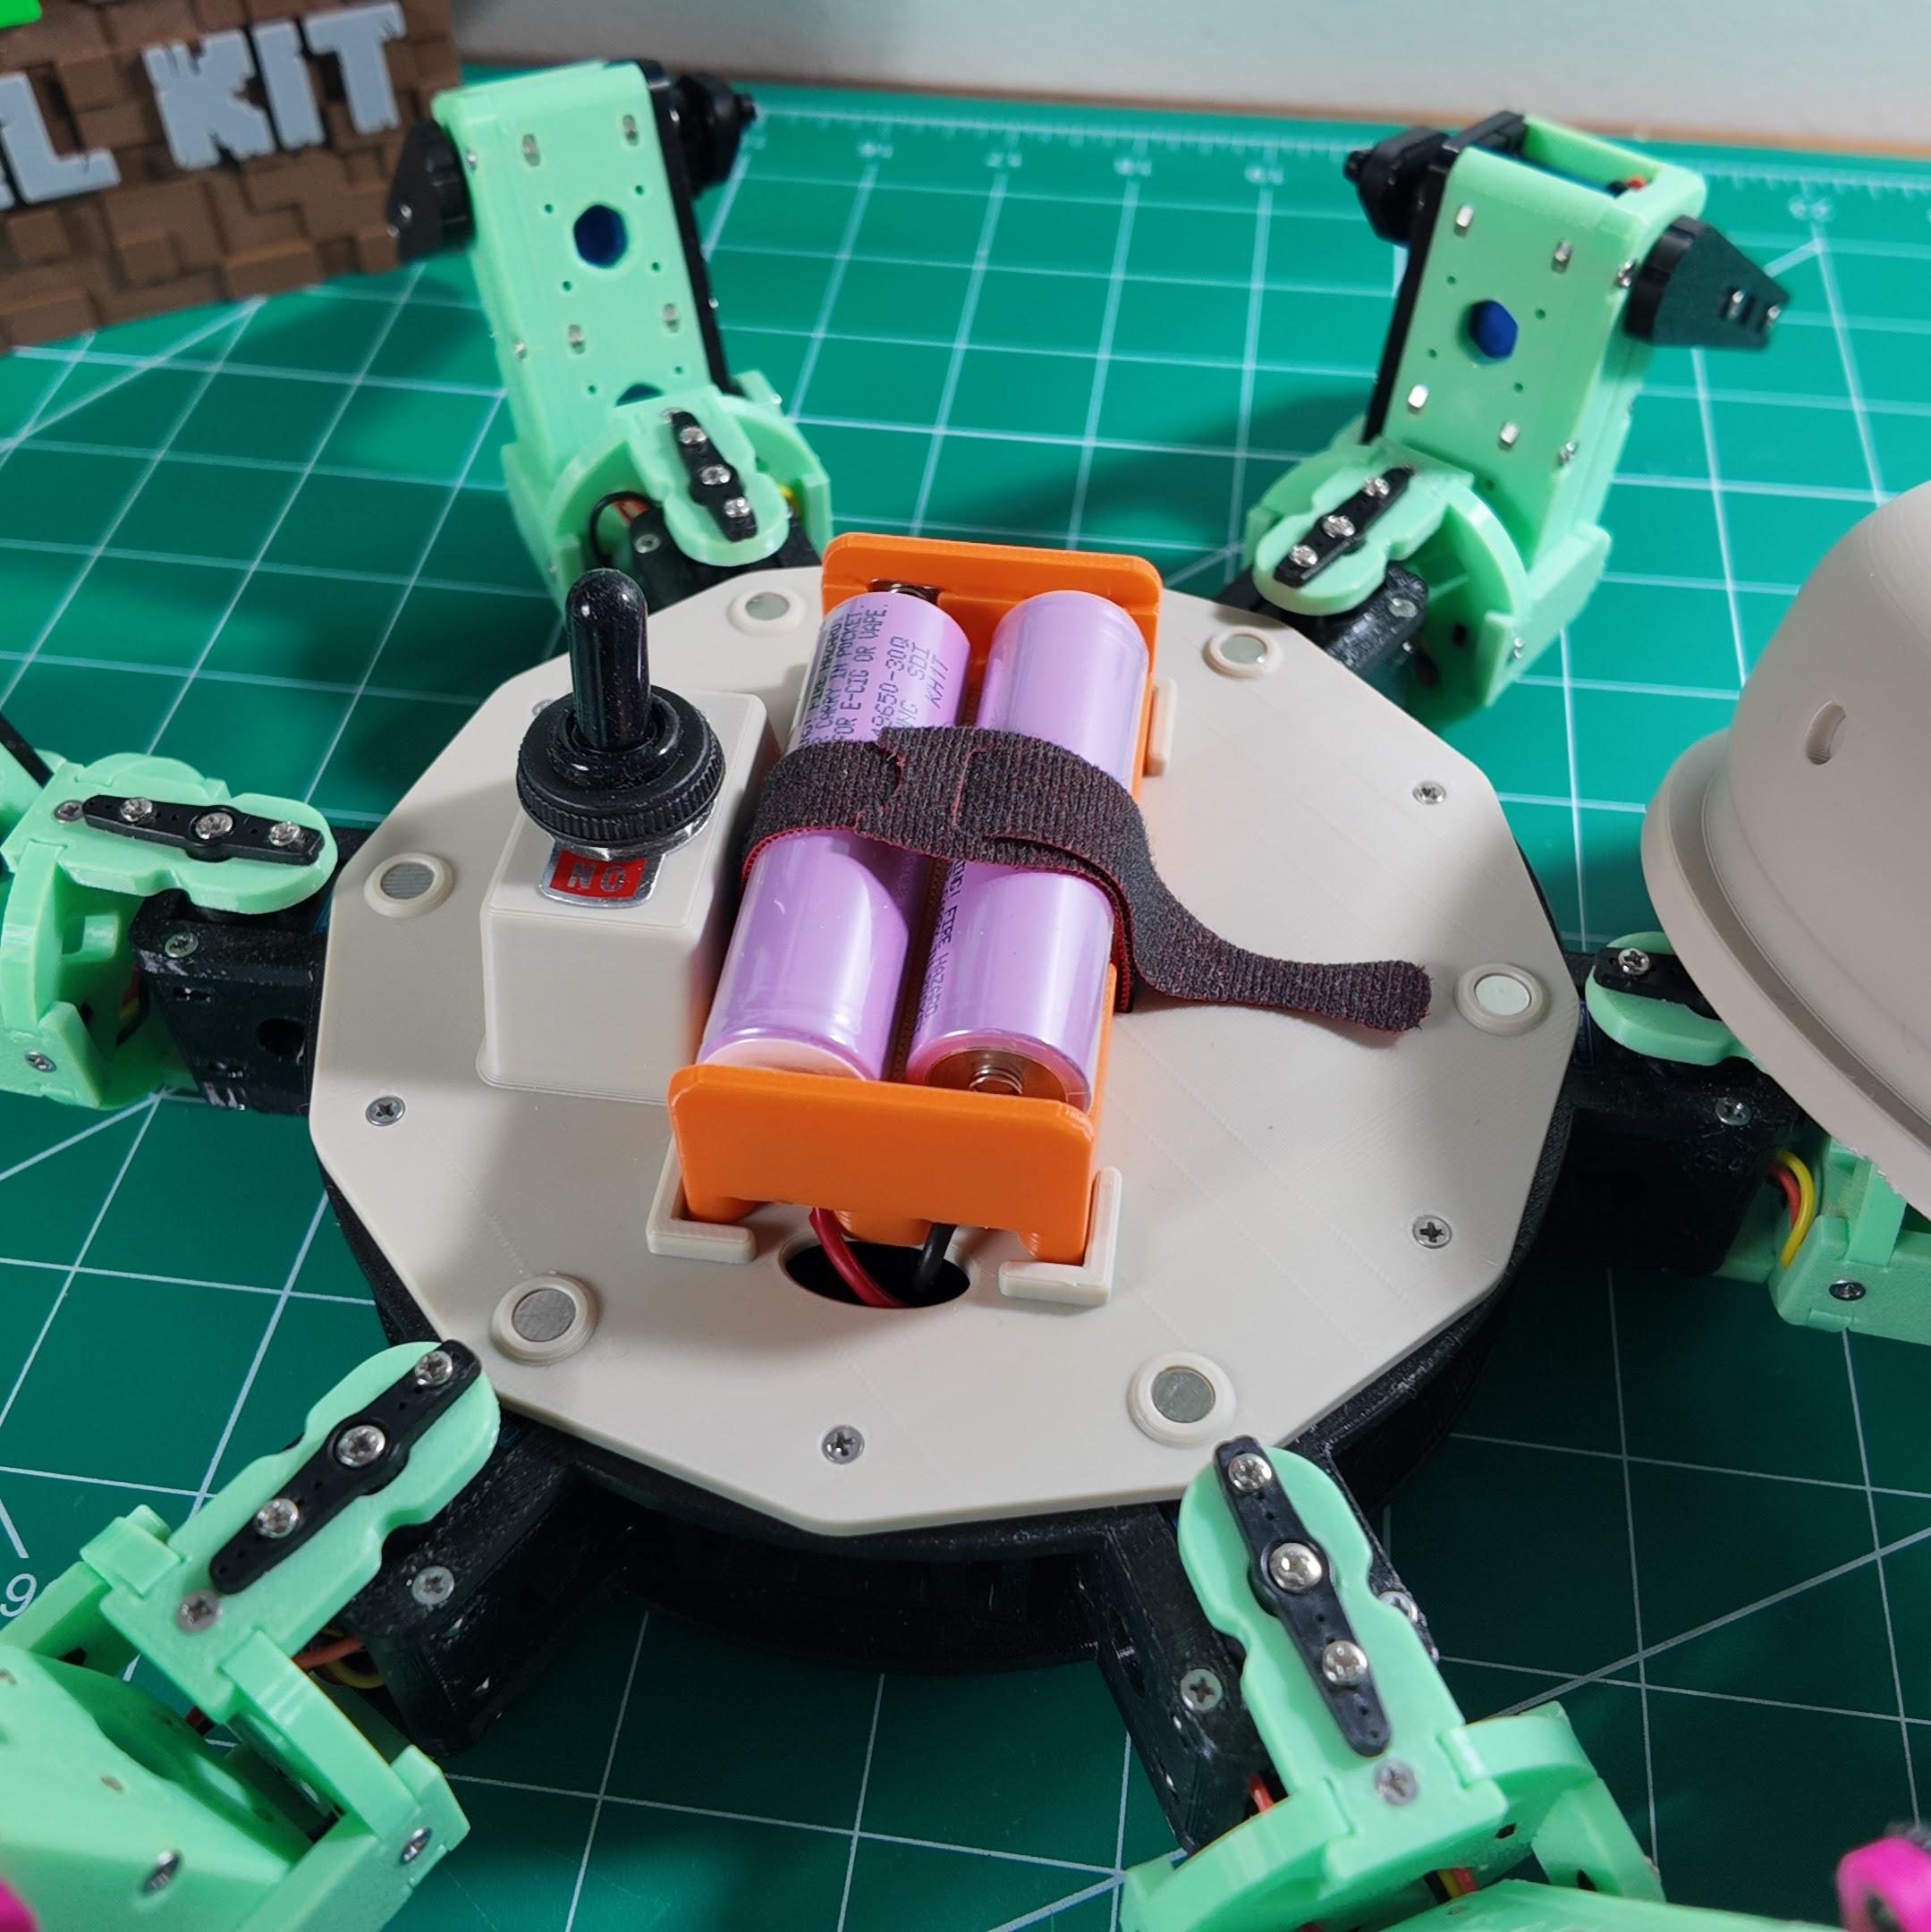
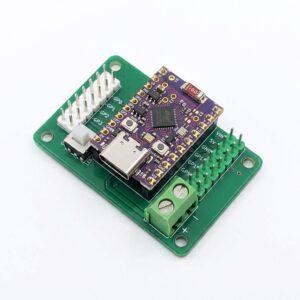
The Hexapod Controller Board (Mochi & Nougat) is the custom ESP32 carrier PCB that powers the RookiDroid Mochi and Nougat hexapods. Every servo header, both PWM drivers, and power distribution are on one board, so you don’t need a breadboard or a pile of jumper wires. Plug in your ESP32 dev board, 18 servos and a 2S 18650 battery pack, flash the open-source firmware, and your hexapod is ready to walk.
Built for 18 Servos at Once
When a hexapod walks, many servos start moving at the same moment and current spikes sharply. Power that can’t keep up causes jitter, weak legs, and ESP32 brownout resets. This board is designed to handle that load.
- 20A high-current power module: a DC-DC converter rated for up to 20A output. It gives all 18 servos plenty of current headroom, even when every leg moves at once. It has built-in over-current, short-circuit, over-temperature and under-voltage lockout protection.
- High-quality aluminum electrolytic capacitors: bulk capacitance on the power rail absorbs sudden current surges from the servos. This keeps the supply stable, so motion stays smooth and the ESP32 doesn’t reset mid-stride.
Key Specs
- Microcontroller: Socket for an ESP32 dev board (not included)
- Servo drivers: 2 × PCA9685 16-channel PWM drivers (I²C 0x40 left bank / 0x41 right bank)
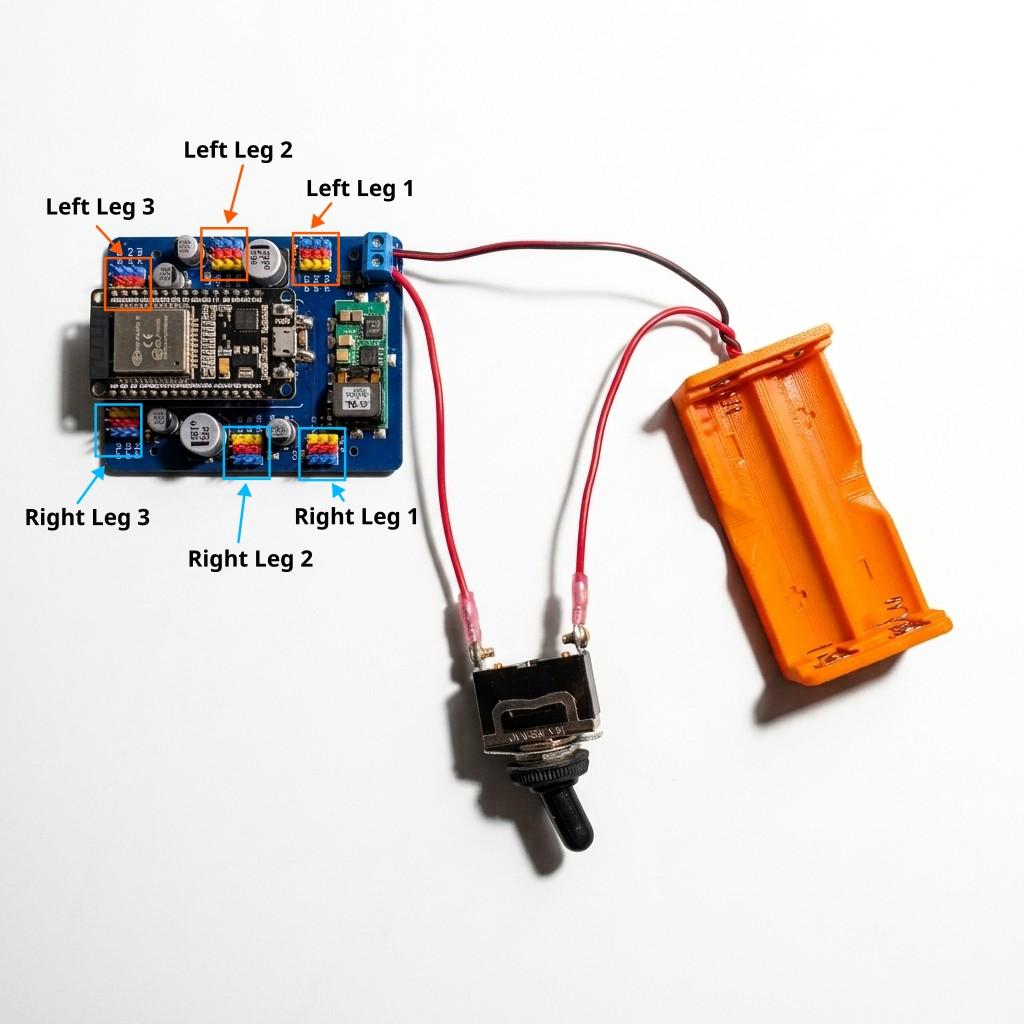
- Servo outputs: 18 numbered headers (3 per leg × 6 legs), each driver bank individually enabled by the ESP32
- Power input: 2-cell 18650 Li-ion pack (7.4V nominal), with a main power switch
- Servo power: 20A DC-DC power module, plus aluminum electrolytic bulk capacitors
- Servo compatibility: MG92B (Mochi) and 21G digital servos (Nougat)
- Control: WiFi UDP at 50 Hz, plus a web-based calibration page at 192.168.4.1
- Firmware: Open-source Arduino (arduino-esp32) with over-the-air (OTA) updates
What’s Included
- Board Only: 1 × Hexapod Controller Board with the PWM drivers and servo headers already assembled
- Board + Battery Holder + Switch: the board, plus a 2-cell 18650 battery holder and an SPST toggle switch (12mm)
- Not included: ESP32 dev board, servos and 18650 batteries
Why This Board
- Power without compromise: a 20A power module and quality electrolytic capacitors keep 18 servos fed and steady.
- Clean wiring: servo connectors and power management are built in. Plug each servo into its numbered port and you’re done.
- No soldering: the PWM drivers and headers are already assembled. Just plug in your ESP32 dev board.
- Wireless from day one: connect to the hexapod’s WiFi network to drive it, calibrate each servo live in your browser, and upload new firmware without a USB cable.
- Calibration that sticks: servo offsets are saved to EEPROM and survive power cycles.
- One board, two robots: the same board and firmware base run both Mochi and Nougat.
Getting Started
- Plug your ESP32 dev board into the controller board’s socket.
- Install Arduino IDE, add
arduino-esp32board support, and install the Adafruit PWM Servo Driver library. - Open
hexapod_esp32.ino, select ESP32 Dev Module, and upload. - Connect the 18 servos and the 2S battery pack, then switch on.
- Join the robot’s WiFi network —
hexapodfor Mochi,hexapod_nougatfor Nougat — and openhttp://192.168.4.1to calibrate.
Safety: use protected 18650 cells only. The protection circuit guards against overcharge, over-discharge, and short circuits.
Open hardware, open firmware. Plug it in and make it walk.
Reviews
There are no reviews yet