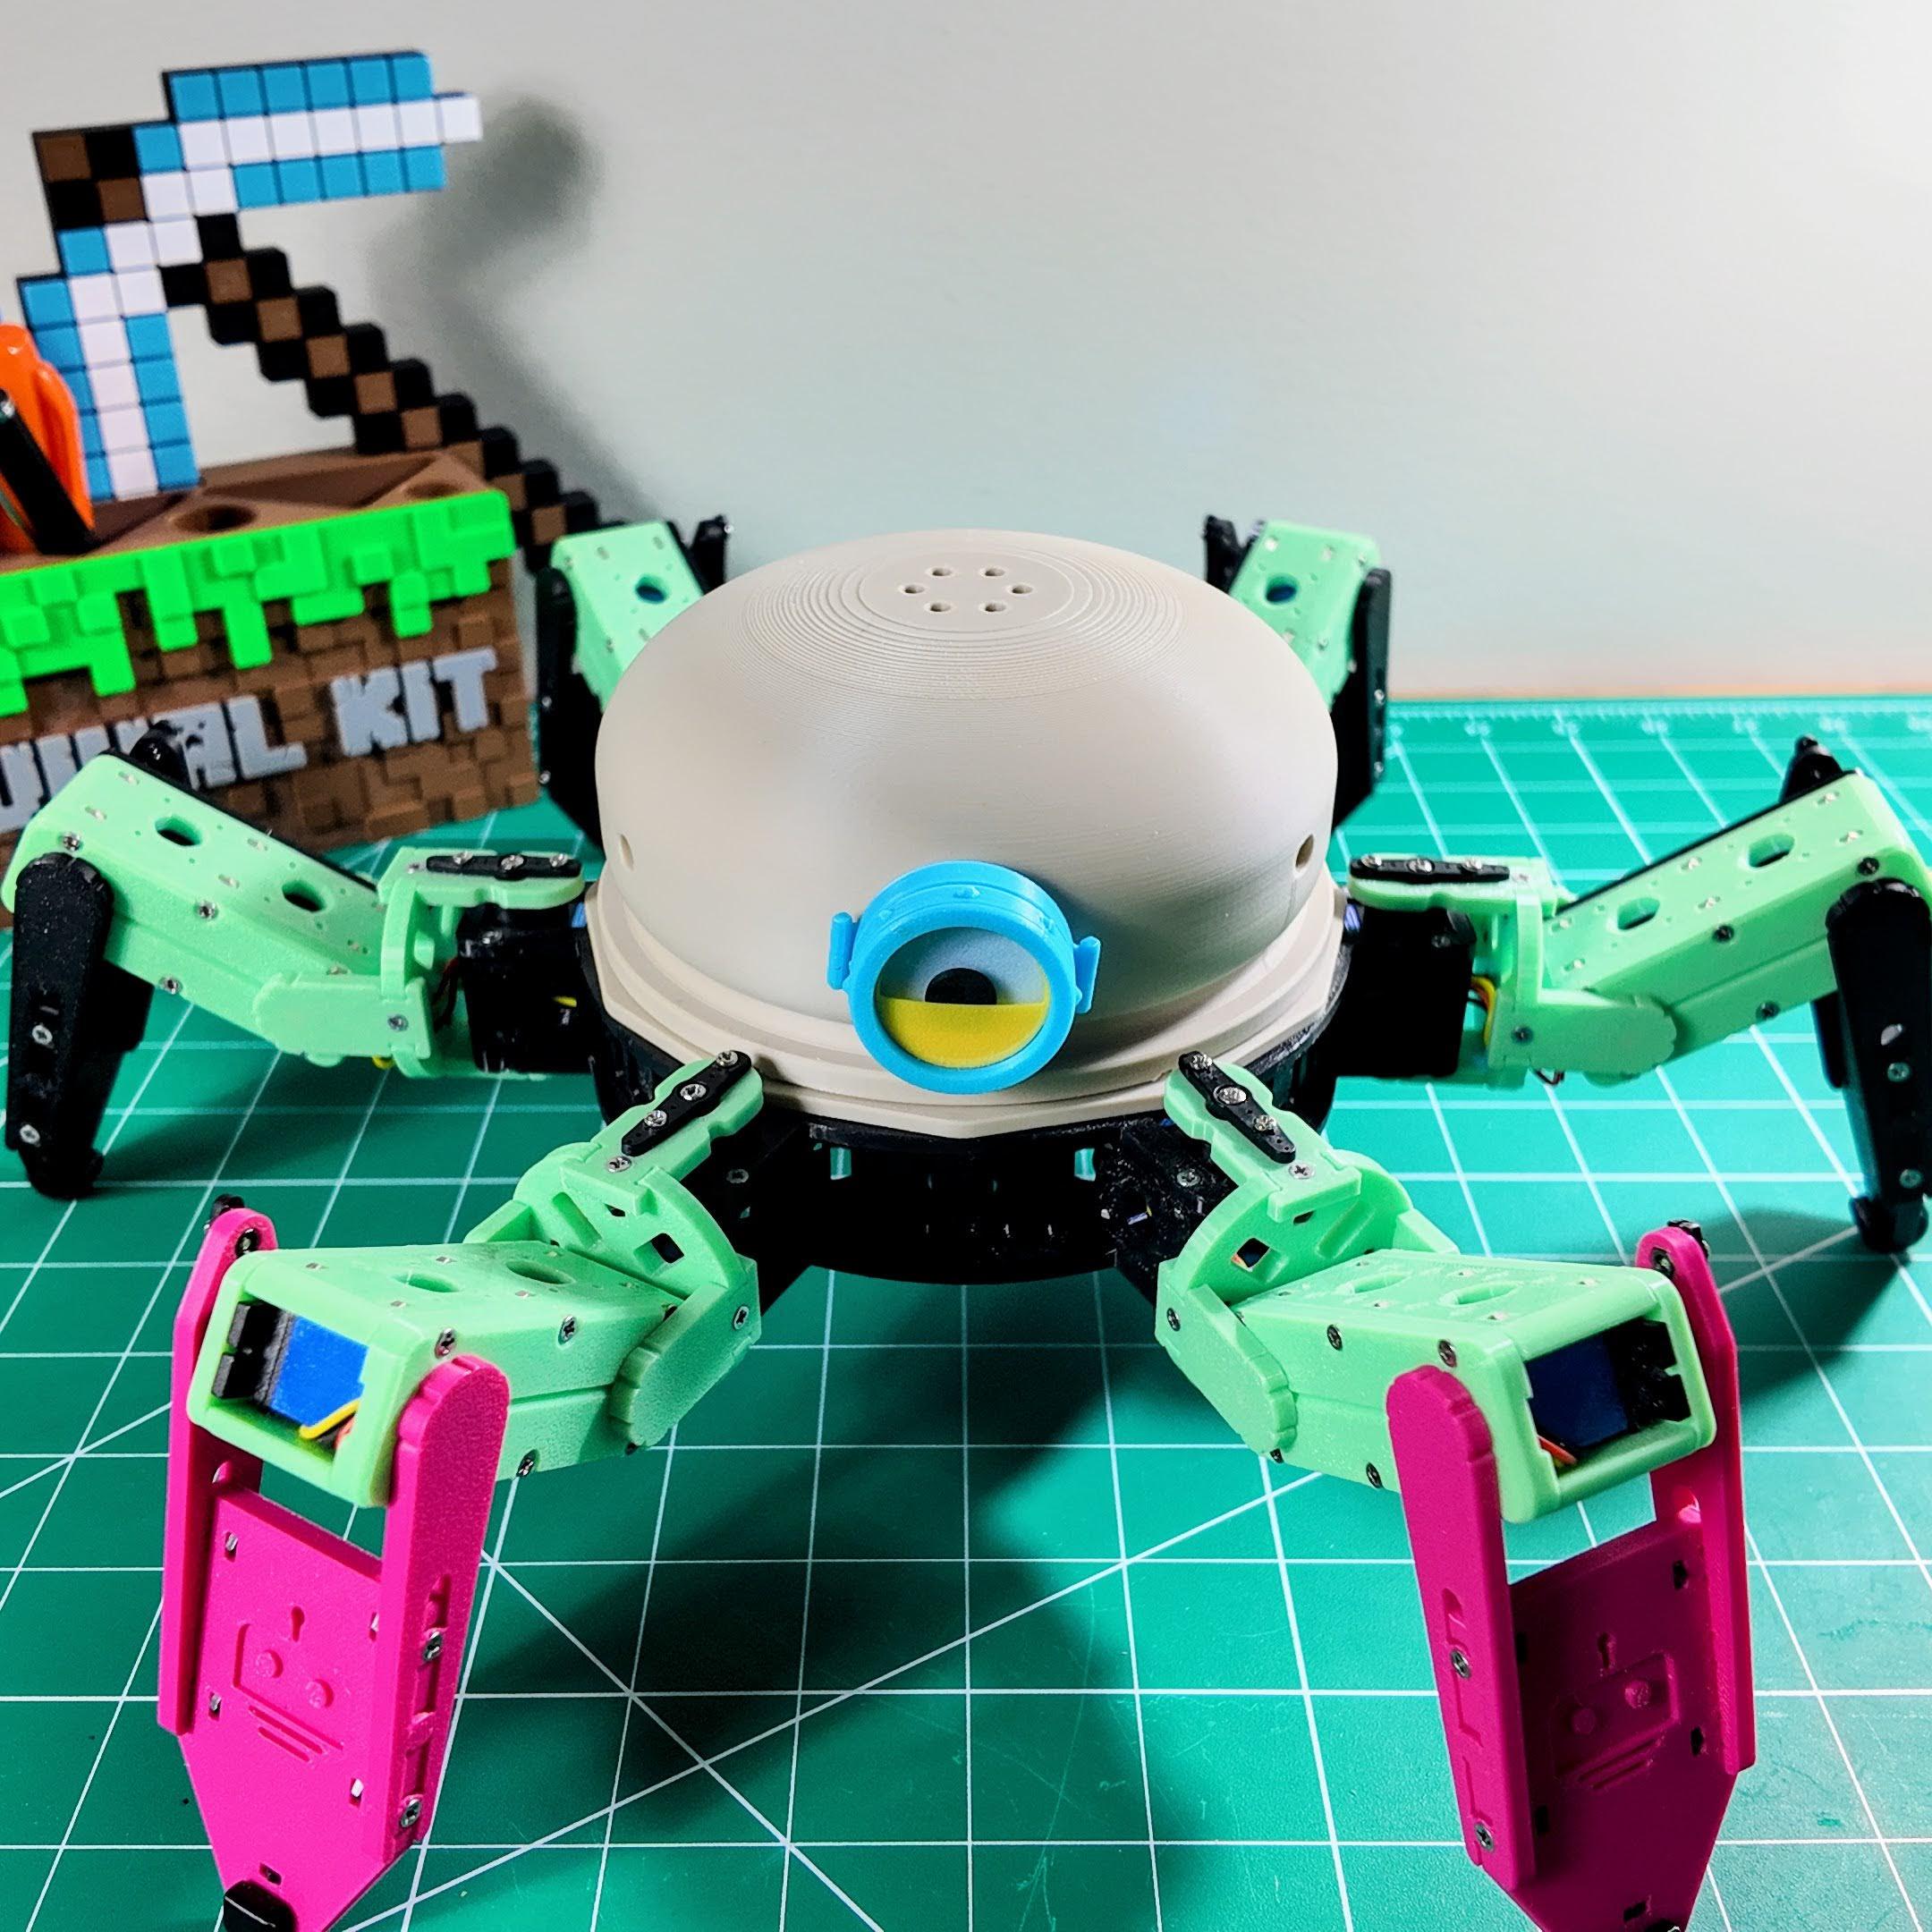
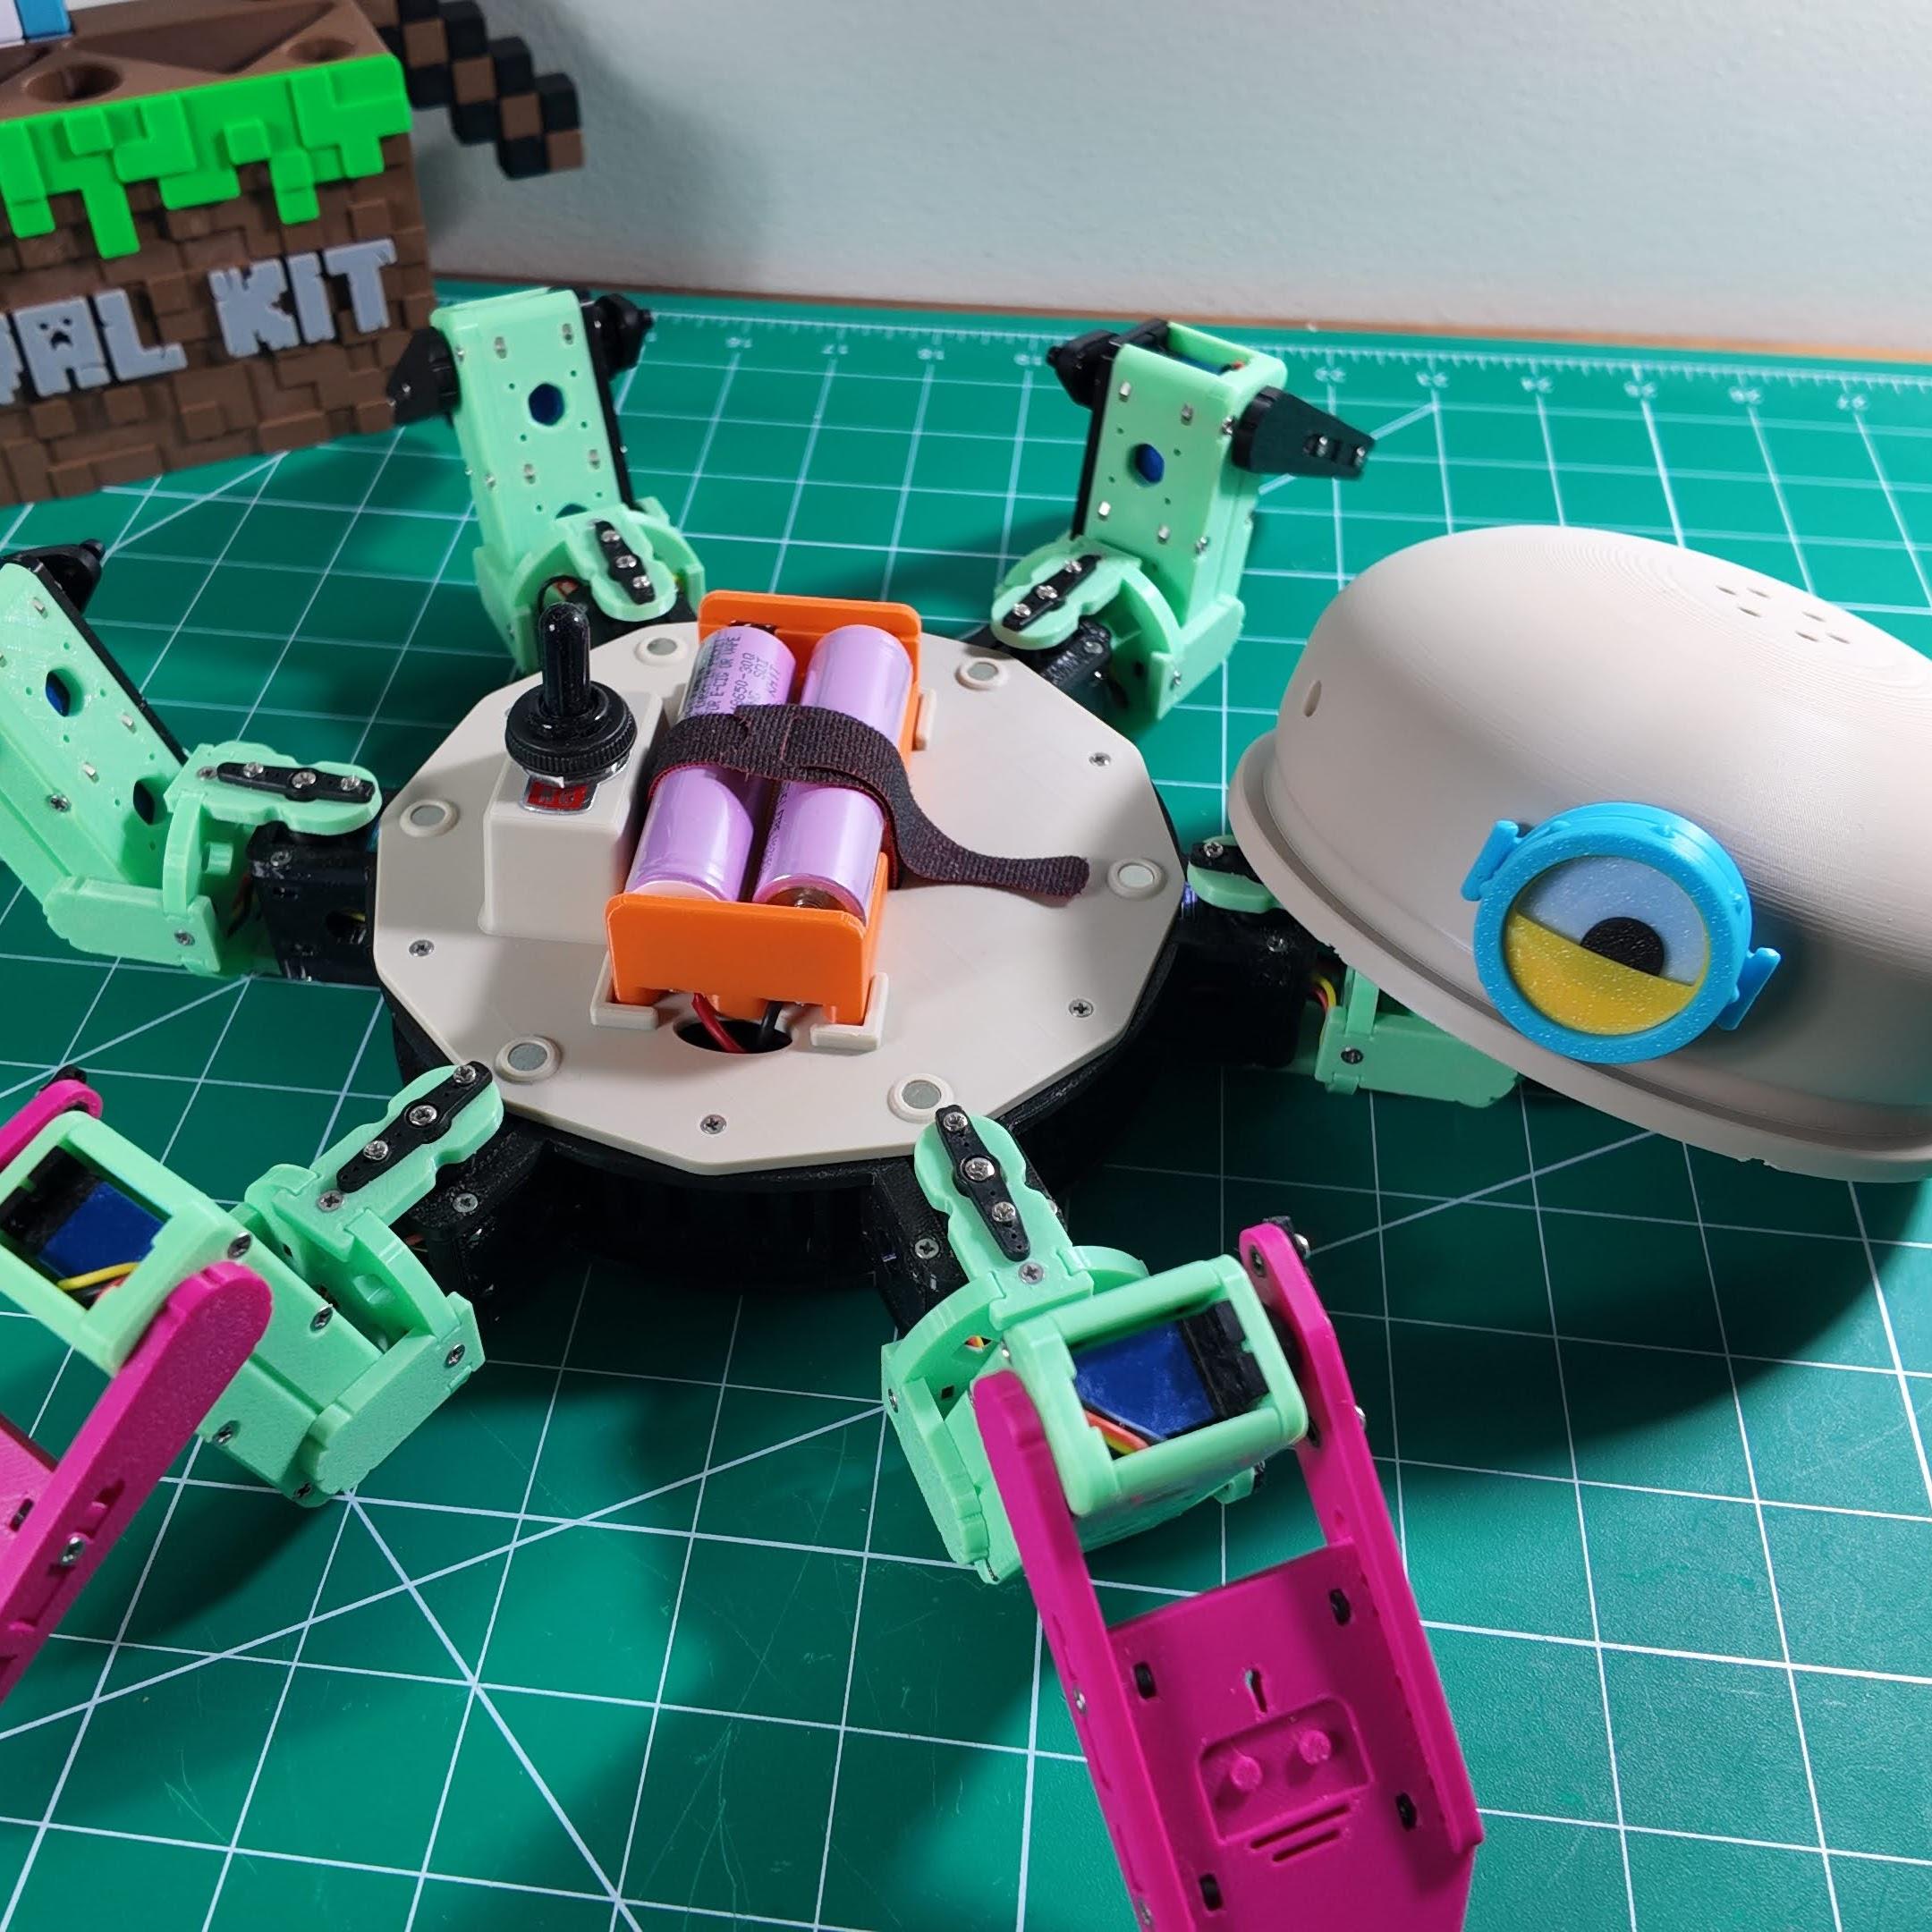
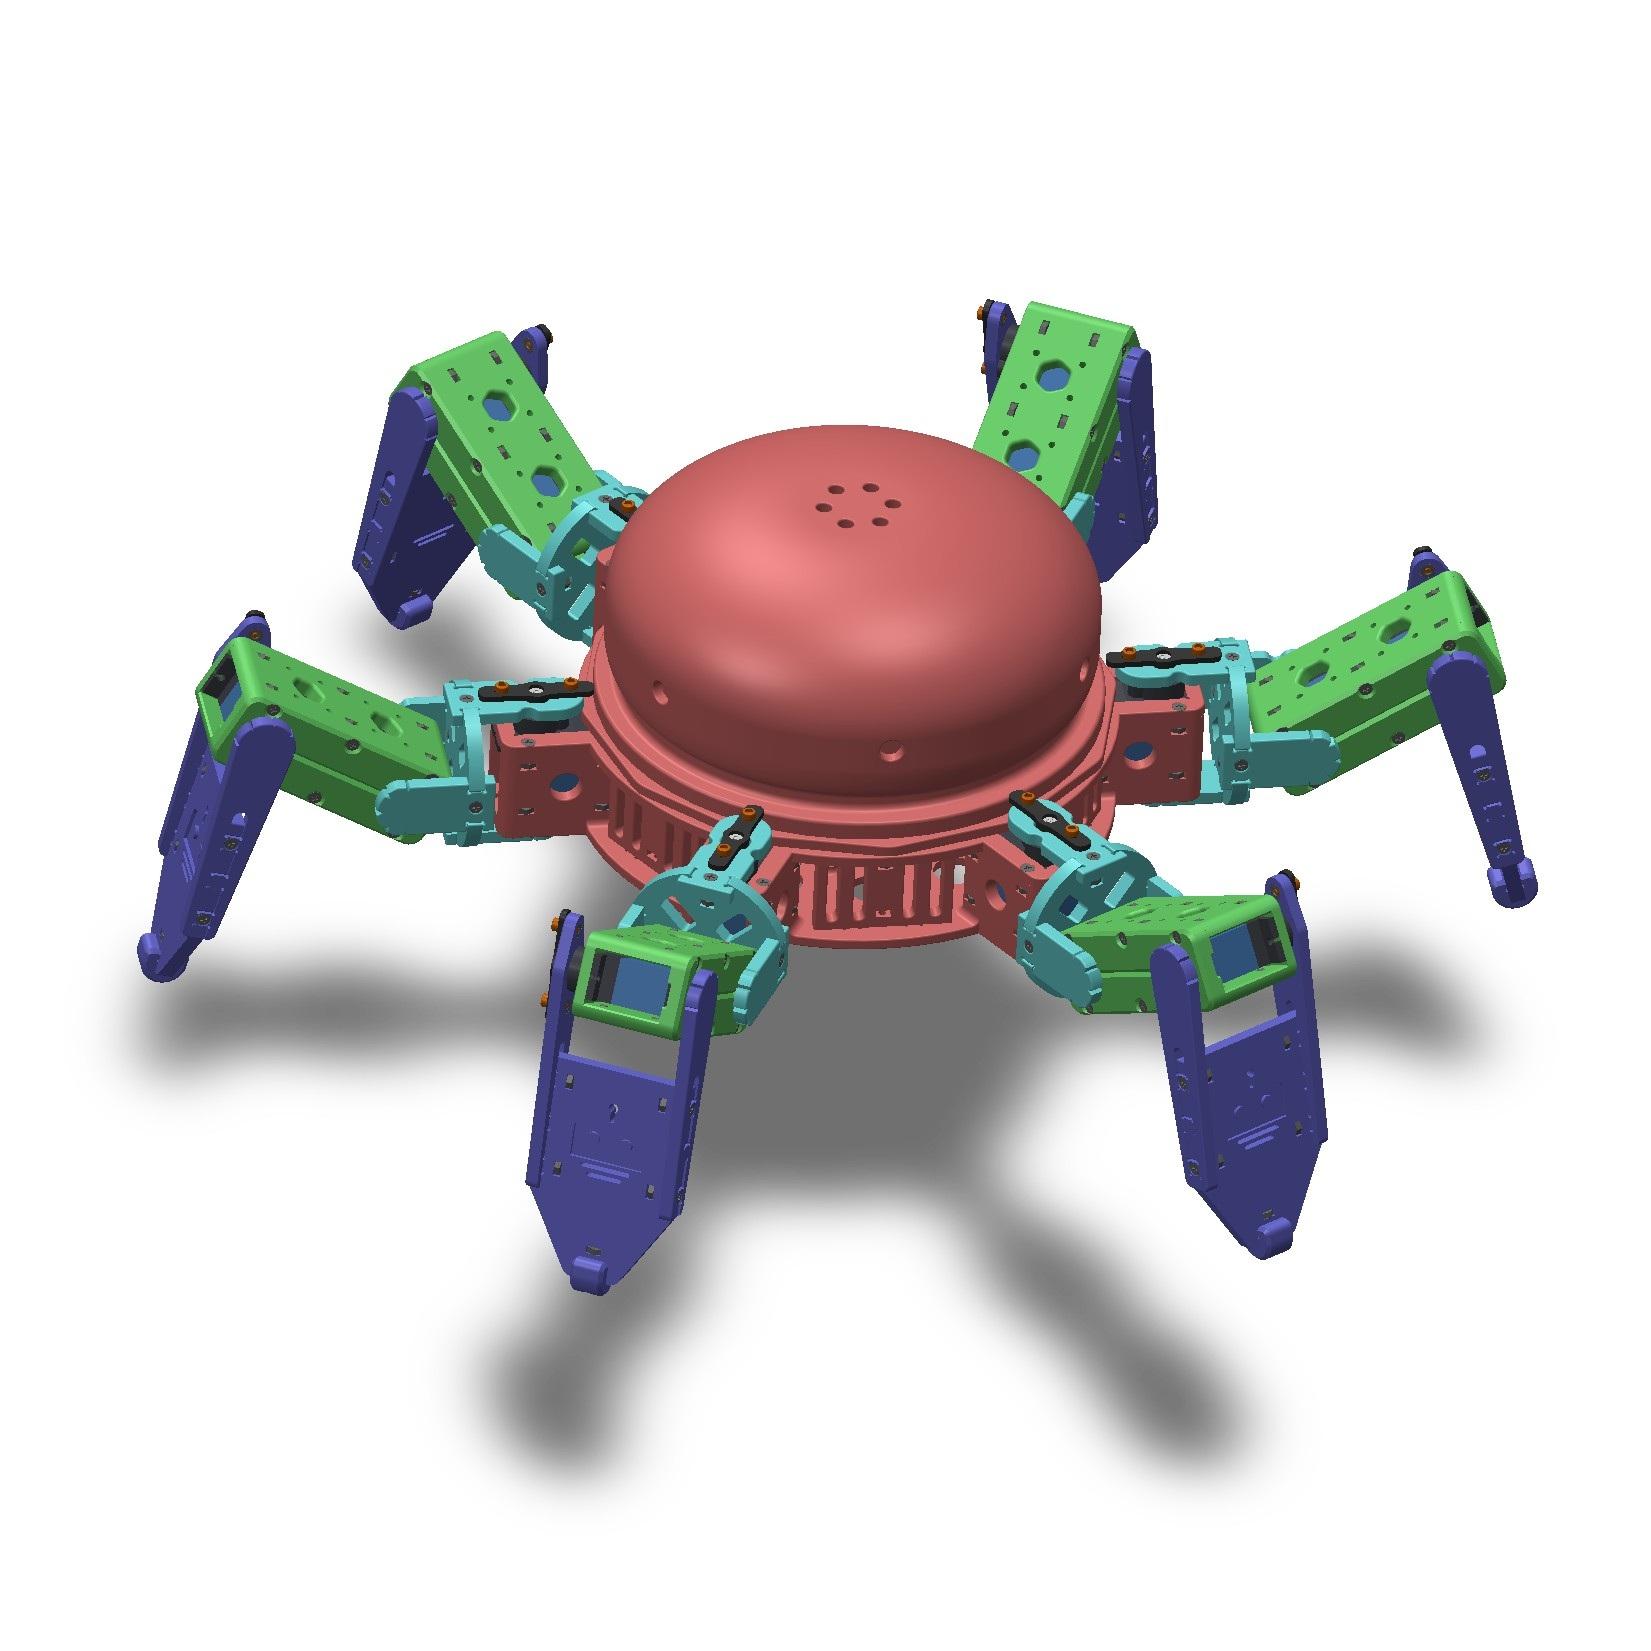
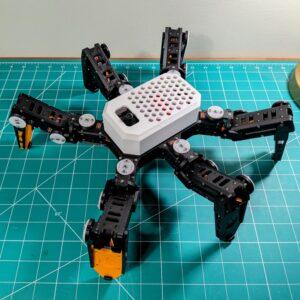
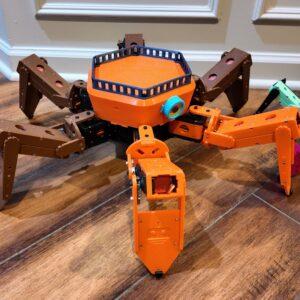
Hexapod Mochi is a six-legged, WiFi-enabled walking robot with 18 degrees of freedom. This listing includes the complete set of 3D-printable model files for the Mochi chassis — designed over three generations to get the geometry, joint strength, and servo fit exactly right. Print it, assemble it, make it walk.
Key Specs
- Legs / DOF: 6 legs · 18 degrees of freedom (coxa, femur and tibia on every leg)
- Servos: 18 × MG92B — highest-torque micro servo that still fits a compact body
- Microcontroller: ESP32 with dual PCA9685 PWM drivers
- Power: 2 × 18650 Li-ion in series (2S) — 7.4V nominal, 8.4V fully charged
- Control: WiFi UDP on its own access point · Android app (point-and-go) · binary protocol with real-time pose streaming at 50 Hz
- Calibration: web page at
http://192.168.4.1, with offsets saved to EEPROM - Firmware: open-source Arduino with over-the-air (OTA) updates
- Materials: PLA or PETG — standard desktop 3D printer friendly, with TPU for the foot tips
- Chassis: circular frame for even load distribution and symmetric gait
What’s Included
- All printable parts for the Mochi chassis (body, joints, legs, feet, servo mounts)
- STL files ready for standard desktop FDM printers, plus a ready-to-slice
hexapod_mochi.3mfBambu Studio project - Compatible with PLA or PETG — no exotic materials needed, though TPU is recommended for the foot tips
What You’ll Need to Finish the Build
The printed parts are one half of the robot. To get it walking you’ll also need:
- 18 × MG92B servos — buy them from the same batch so they behave consistently
- A controller board and an ESP32 dev board
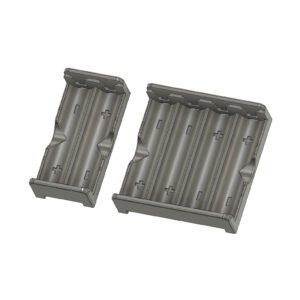
- 2 × protected 18650 cells and a 2-cell holder, plus an SPST toggle switch
- Hardware: 36 × M2×6mm hex socket screws, 180 × M2×12mm countersunk screws, 216 × M2 nuts, 18 × M4×6mm pins and 18 × MR74-2RS bearings
- Tools: a hex key set and a small screwdriver. No soldering is needed with the pre-assembled controller board
Designed to Last
Every structural decision in Mochi was deliberate:
- Layer orientation — print layers align with load directions to prevent delamination under walking forces.
- Reinforced joints — servo mounts and leg segments spread loads to minimise stress concentrations.
- Circular frame — optimises the weight-to-rigidity ratio and distributes servo loads evenly across all six legs.
- Modular assembly — interlocking parts reduce adhesive dependency; repairs and upgrades need no specialised tools.
Wireless From Day One
The open-source ESP32 firmware gives Mochi everything it needs without a cable in sight:
- 19 built-in motions — standby, walking at six headings, fast walk, turns in place, a climbing gait, body pitch / roll / yaw and twist.
- Real-time pose streaming — drive all 18 joints live from a computer at 50 Hz, with per-joint slew limiting and a 1-second failsafe.
- Browser calibration — set every servo offset live at
http://192.168.4.1; values persist in EEPROM across power cycles. - OTA updates — upload new firmware over WiFi, no USB cable needed.
Built to Teach
Mochi is a platform, not just a model. Once printed and assembled it becomes a working robot that teaches real skills: electronics, ESP32 programming, gait mathematics, and WiFi control — all documented step by step on the RookiDroid site.
Three generations of iteration. One set of files. Print it and make it walk.
Reviews
There are no reviews yet