
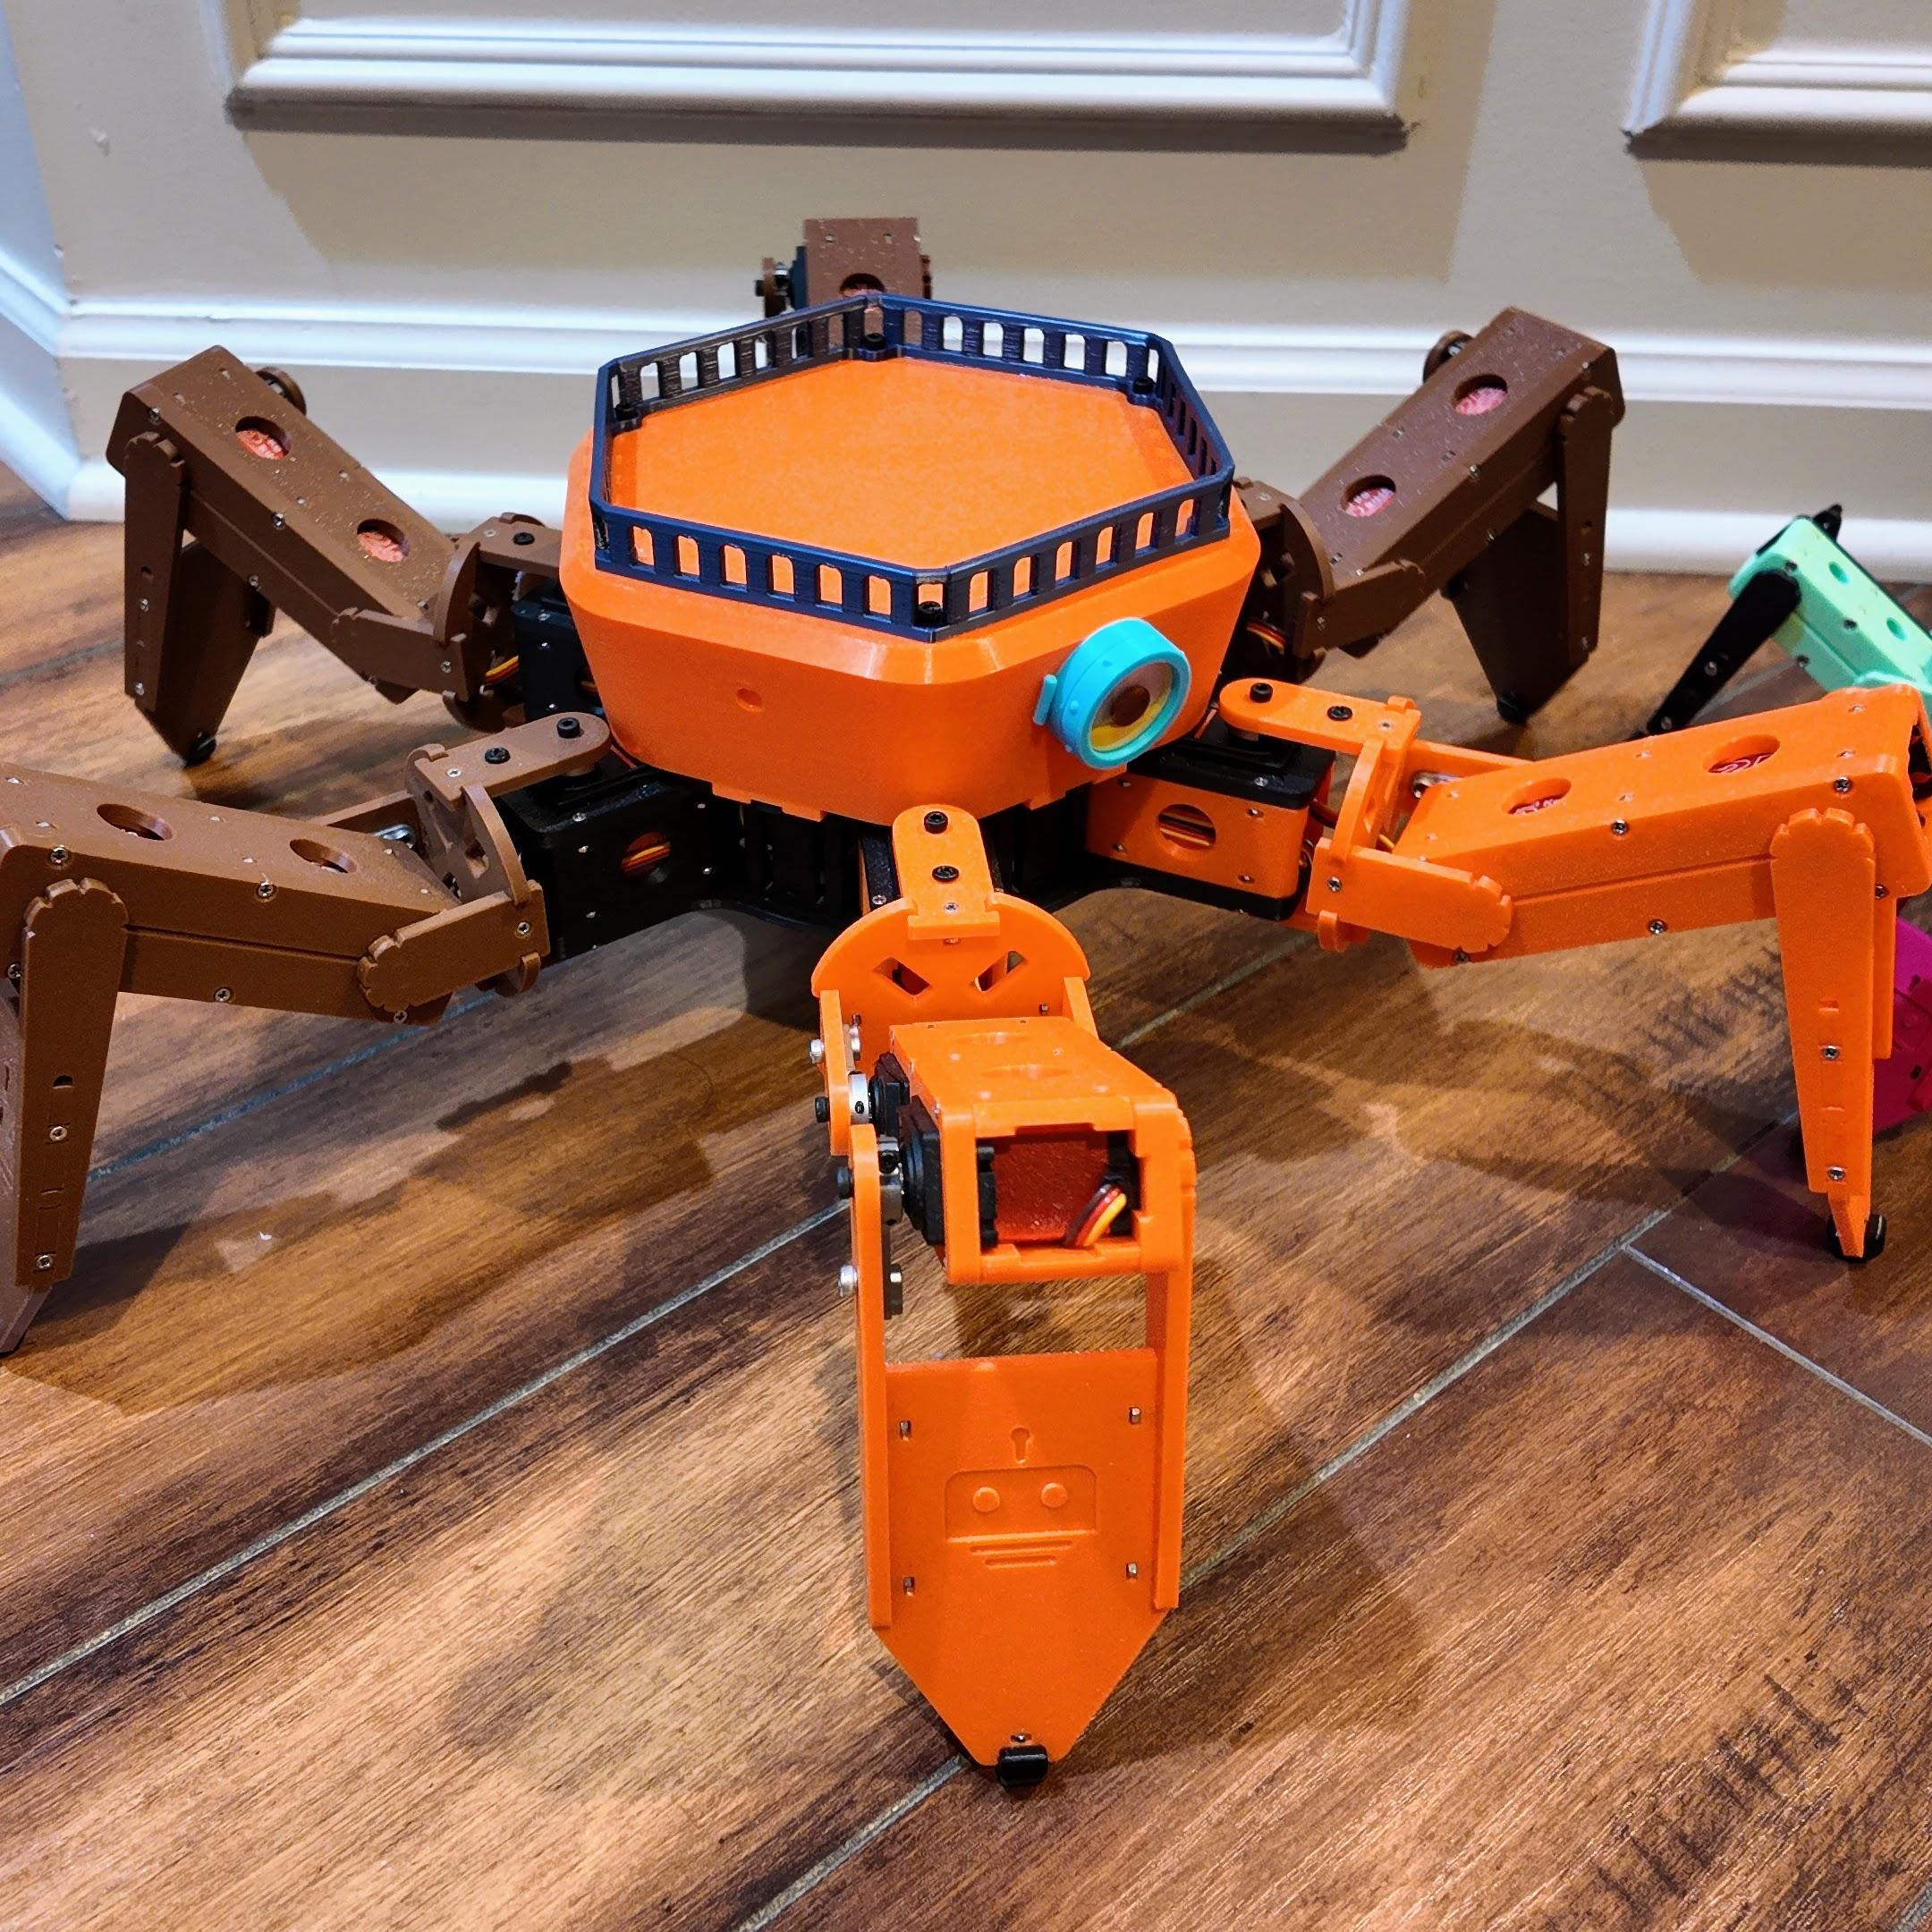
Hexapod Macaroon is a six-legged, WiFi-enabled walking robot with 18 degrees of freedom — the largest and strongest of the RookiDroid hexapods. This listing includes the complete set of 3D-printable model files for the Macaroon chassis, built around 25kg servos and a four-cell battery pack. Print it, assemble it, make it walk.
Key Specs
- Legs / DOF: 6 legs · 18 degrees of freedom (coxa, femur and tibia on every leg)
- Servos: 18 × 25kg digital servos, 180° rotation — they must support an 8.4V supply, because the batteries drive them directly
- Microcontroller: ESP32 with dual PCA9685 PWM drivers (I²C 0x40 left bank / 0x41 right bank)
- Power: 4 × 18650 Li-ion in 2S2P — 7.4V nominal, 8.4V fully charged
- Control: binary UDP protocol on its own access point · Android app (point-and-go) · real-time pose streaming at 50 Hz
- Calibration: web page at
http://192.168.4.1, with offsets saved to EEPROM - Resolution: ~0.44° per servo tick (410 ticks over 180°)
- Firmware: open-source Arduino with over-the-air (OTA) updates
- Materials: PLA or PETG — standard desktop 3D printer friendly, with TPU for the foot tips
- Chassis: circular frame for even load distribution and symmetric gait
What’s Included
- All printable parts for the Macaroon chassis (body, joints, legs, feet, servo mounts), plus an optional fence
- STL files ready for standard desktop FDM printers, plus ready-to-slice Bambu Studio projects for the body, joints, legs and feet
- Compatible with PLA or PETG — no exotic materials needed, though TPU is recommended for the foot tips
What You’ll Need to Finish the Build
The printed parts are one half of the robot. To get it walking you’ll also need:
- 18 × 25kg servos rated for 8.4V — buy them from the same batch so they behave consistently
- A Macaroon controller board and an ESP32 dev board
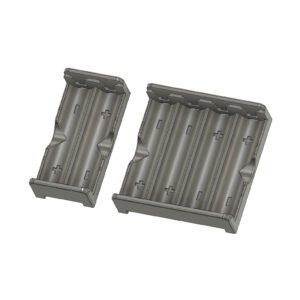
- 4 × protected 18650 cells and a 2S2P holder, plus an SPST toggle switch (12mm)
- Hardware: 36 × M2×6mm hex socket screws, 180 × M2×12mm countersunk screws, 216 × M2 nuts, 18 × M4×6mm pins and 18 × MR74-2RS bearings
- Tools: a hex key set and a small screwdriver. No soldering is needed with the pre-assembled controller board
Designed to Last
Every structural decision in Macaroon was deliberate:
- Layer orientation — print layers align with load directions to prevent delamination under walking forces.
- Reinforced joints — servo mounts and leg segments spread loads to minimise stress concentrations.
- Circular frame — optimises the weight-to-rigidity ratio and distributes servo loads evenly across all six legs.
- Modular assembly — interlocking parts reduce adhesive dependency; repairs and upgrades need no specialised tools.
Built for Torque
Macaroon is the heavy-duty member of the family, and the electronics are sized to match:
- 25kg servos, driven directly — the Macaroon controller board feeds the servos straight from the 2S pack, so they get the full 8.4V at full charge.
- Four cells in 2S2P — double the capacity of the two-cell builds, for longer sessions between charges.
- 19 built-in gaits — walking at six headings, fast walking, turning in place, a climbing gait, body pitch / roll / yaw and twist.
- Real-time pose streaming — drive all 18 joints live from a computer at 50 Hz, with per-joint slew limiting and a 1-second failsafe.
Built to Teach
Macaroon is a platform, not just a model. Once printed and assembled it becomes a working robot that teaches real skills: electronics, ESP32 programming, gait mathematics, and WiFi control — all documented step by step on the RookiDroid site.
Safety: use protected 18650 cells only, charge with a proper 2S charger, and check battery polarity twice before the first power-up. Eighteen 25kg servos have enough torque to pinch hard — keep fingers clear of the joints when the robot is powered.
The biggest of the three. Print it and make it walk.
Reviews
There are no reviews yet